

Advanced DC motor Controller
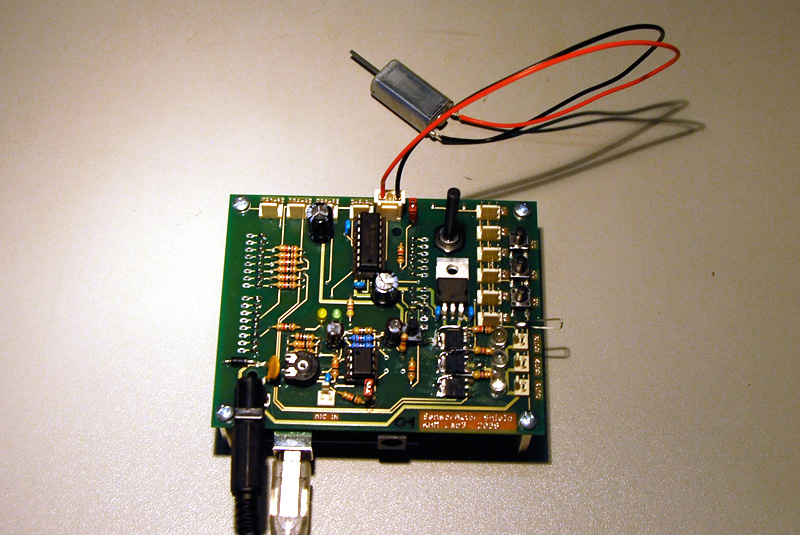
Basic example based on the › simple DC motor controller using the built-in L293 chip of the SensorAktor-Shield. One of the built-in switches is used to set the direction of the motor. Have a look on the › switch LED example how to use a switch button.
/* advanced motor controller

 *
 * control speed and direction of a motor
 *

 * SensorAktor Workshop
 * Lab3 2008
 * Kunsthochschule fuer Medien Koeln
 * Academy of Media Arts Cologne
 * http://interface.khm.de

 * pin mapping SensorAktor Shield
 * import SensorAktor.h to get already defined mapping
 *
 * analog inputs: analog0 = pin0, analog1 = pin1, analog2 = pin2,
 * analog3 = pin3, analog4 = pin4, analog5 = pin5
 * built-in poti: poti = pin5
 * amplified input: mic = pin0
 * switches: switch1 = pin1, switch2 = pin2, switch3 = pin3
 * leds: led1 = pin3, led2 = pin5, led3 = pin6
 * power outs: out1 = pin3, out2 = pin5, out3 = pin6
 * motor outs: motor1_1 = pin8, motor1_2 = pin13, motor2_1 = pin11, motor2_2 = pin12
 * motor pwms: pwmMotor1 = pin10, pwmMotor2 = pin9
 * servo outs: servo1 = pin2, servo2 = pin4, servo3 = pin7

 */

// import sensor aktor library for pin mapping
#include <SensorAktor.h>

// import motor library
#include <MotorL293.h>
// create instance for motor
MotorL293 myMotor;

// poti value
int potiValue = 0;

// this block is executed one time when programm starts
void setup(){

  // set pin modes
  pinMode(switch1,INPUT);

  // turn on pullup resistor for switch 1
  digitalWrite(switch1, HIGH);

  // attach pins to motor (motor pin1, motor pin2, pwm pin motor)
  myMotor.attach(motor1_1, motor1_2, pwmMotor1);

}

// this block is executed in a loop after setup is called one time
void loop(){

  // read poti (value between 0 and 1023)
  potiValue = analogRead(poti);
  // scale poti value to use it with setPower (value between 0 and 254)
  potiValue = map(potiValue, 0 , 1023, 0, 254);

  // set speed of motor using poti value (value between 0 and 254)
  myMotor.setPower(potiValue);

  // use switch 1 to set direction of motor 1 (0=left, right=1)
  if(digitalRead(switch1) == HIGH){
    myMotor.setDirection(0);
  }
  else{
    myMotor.setDirection(1);
  }

}
Files needed
Since Arduino 0015 there are some problems with the old “SensorAktor.h” file.
Use this one instead.